| 1. Define the Application Before Selecting a Supplier |
| Load type and payload |
Unit loads may range from small totes to loaded pallets. Record the maximum gross load, load dimensions, center of gravity, and whether the load is stable during acceleration. |
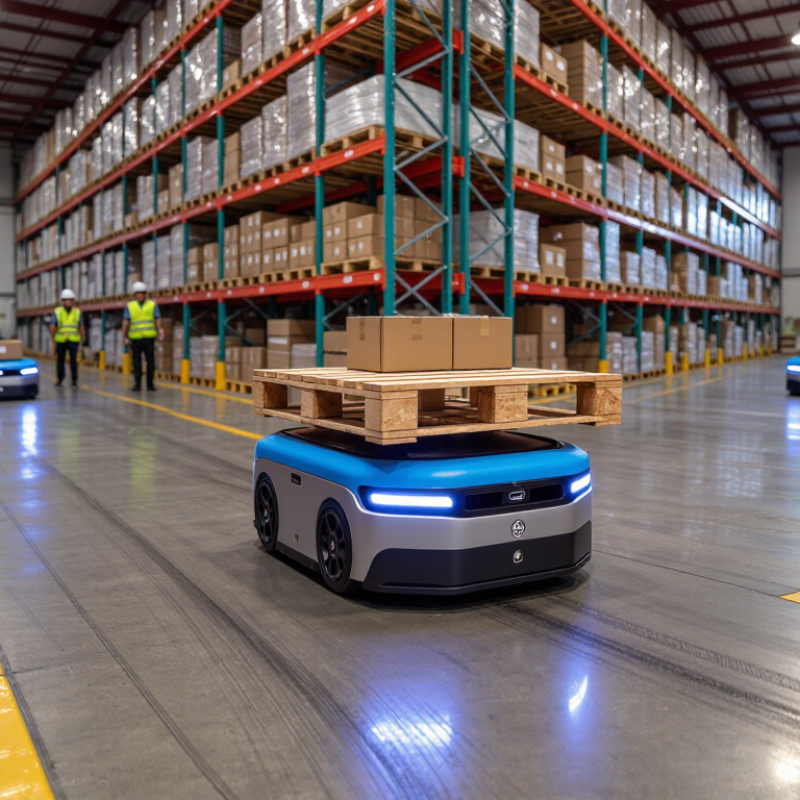
Use a unit-load vehicle for totes and cartons, a pallet transporter for floor-level pallets, or a forklift AGV for rack and pallet handling. |
Confirm published payload ratings, load-transfer tolerances, fork dimensions, attachment options, and performance at the maximum rated load. |
Measure at least 50 representative loads and test the heaviest and most irregular loads during the site trial. |
High |
| Travel distance and route layout |
Map one-way distance, intersections, turning radii, aisle width, gradients, floor joints, pedestrian crossings, and pickup/drop-off points. |
Choose the navigation method that suits the environment: fixed guidance for stable routes or natural-feature navigation for layouts that may change. |
Assess route-editing tools, map update procedures, obstacle-handling performance, and the ability to manage mixed traffic. |
Complete a digital or physical route survey before final quotation. Include the longest route and the most congested area. |
High |
| Throughput requirement |
Calculate required moves per hour, peak-hour demand, average travel distance, loading time, unloading time, waiting time, and expected availability. |
Select the fleet size using a workload model rather than vehicle speed alone. Include spare capacity for peaks and charging or maintenance downtime. |
Request a simulation or validated capacity calculation using the customer’s actual routes, handling times, and traffic rules. |
Set acceptance criteria for completed moves per hour, average response time, queue length, and order-priority compliance. |
High |
| Operating hours and battery strategy |
Document shift pattern, daily operating hours, charging windows, battery chemistry, ambient temperature, and required availability. |
Use opportunity charging for continuous or multi-shift operations when the vehicle and battery system support it; use scheduled charging for predictable single-shift workflows. |
Verify battery runtime under the actual payload and route profile, charging cycle limits, battery replacement process, and charging-station safeguards. |
Allow charging locations to remain clear of emergency exits, pedestrian bottlenecks, heat sources, and wet-process areas. |
High |
| Floor and environmental conditions |
Check floor flatness, load-bearing capacity, surface condition, dust, moisture, temperature, lighting, and reflective or transparent surfaces. |
Specify suitable wheels, sensors, protection rating, and environmental options. Do not assume an indoor vehicle is suitable for outdoor or washdown areas. |
Review environmental operating limits, sensor performance, floor tolerances, and documented test results for similar conditions. |
Perform a floor inspection and test navigation at ramps, expansion joints, dock plates, and other transition points. |
High |
| Human and vehicle interaction |
Identify pedestrian density, manual forklifts, crossing points, blind corners, emergency routes, and areas requiring controlled access. |
Use a configuration with appropriate detection, speed management, audible and visual warnings, and defined right-of-way rules. |
Review safety functions, risk-assessment support, safety documentation, stop-distance data, and integration with site traffic controls. |
Complete a formal risk assessment and validate protective functions before production use. Safety functions should not be bypassed to increase throughput. |
High |
| 2. Select the AGV Supplier Using Evidence-Based Criteria |
| Solution fit and scalability |
Define the initial fleet size, expected volume growth, additional vehicle types, future facilities, and possible route changes. |
Prefer a modular fleet architecture that can add vehicles, stations, missions, and traffic zones without replacing the control platform. |
Request references for comparable payloads, environments, fleet sizes, and integration complexity. Evaluate both current fit and expansion cost. |
Include expansion interfaces, spare capacity, software licensing assumptions, and future site requirements in the contract. |
High |
| Fleet management and software |
Required functions may include mission dispatching, traffic control, battery monitoring, map management, alarms, reporting, and user permissions. |
Choose a fleet manager that can prioritize missions, prevent traffic conflicts, and provide operational data through standard interfaces where required. |
Demonstrate dashboard usability, alarm history, audit trails, role-based access, offline behavior, software update procedures, and data export options. |
Define key performance indicators such as move completion rate, vehicle utilization, blocked time, charging time, and fault recovery time. |
High |
| Integration capability |
Potential interfaces include warehouse management, manufacturing execution, enterprise resource planning, conveyor controls, elevators, doors, and automatic storage systems. |
Use standardized communication interfaces where practical and clearly define message ownership, acknowledgement rules, and failure handling. |
Assess integration experience, interface documentation, test environments, cybersecurity controls, and responsibility for third-party equipment. |
Create an interface control document covering data fields, timing, retries, exceptions, access rights, and acceptance tests. |
High |
| Safety and regulatory support |
Safety requirements depend on the country, site layout, vehicle type, load, and interaction with employees and other equipment. |
Select equipment designed for the applicable machinery, electrical, electromagnetic compatibility, and workplace safety requirements. |
Request the declaration of conformity or equivalent documentation, risk-assessment inputs, safety validation records, manuals, and training materials. |
Have qualified personnel approve the site risk assessment, safety zones, emergency procedures, signage, and operator training before go-live. |
High |
| Service and spare parts |
Identify required response time, maintenance window, local technical coverage, critical spare parts, and internal maintenance capability. |
Specify preventive maintenance intervals, remote support arrangements, diagnostic access, and a defined escalation process. |
Compare service-level commitments, technician coverage, spare-parts lead times, training, warranty exclusions, and lifecycle support. |
Maintain a spare-parts list and service calendar. Record mean time to repair, recurring faults, and first-time fix rate after launch. |
High |
| Total cost of ownership |
Include vehicles, batteries, chargers, software, integration, site preparation, training, maintenance, spare parts, and future expansion. |
Compare alternatives using cost per completed move and five-year operating cost, not only the initial vehicle price. |
Require a transparent commercial model covering recurring software fees, support fees, consumables, upgrades, and ownership of operational data. |
Build a financial model using conservative throughput, realistic labor savings, maintenance costs, and planned downtime. |
High |
| 3. Recommended Implementation Plan |
| Phase 1: Process discovery |
Document current-state material flows, task frequency, cycle times, exception cases, safety risks, and manual workarounds. |
Start with repetitive, rule-based transport tasks that have stable pickup and drop-off points. |
Supplier should provide a site survey, process map, assumptions register, preliminary risk review, and solution concept. |
Approve a baseline containing throughput, labor hours, error rate, travel distance, and service-level requirements. |
High |
| Phase 2: Simulation and pilot design |
Model normal demand, peak demand, charging behavior, traffic congestion, equipment downtime, and recovery from blocked routes. |
Design a limited pilot with a manageable number of vehicles and a clearly bounded operating area. |
Supplier should disclose model assumptions and provide sensitivity results showing the effect of volume and travel-time changes. |
Define pilot success thresholds before equipment delivery, including safety, throughput, availability, and user acceptance. |
High |
| Phase 3: Site preparation |
Prepare floors, charging points, network coverage, safety markings, access controls, interfaces, staging areas, and emergency procedures. |
Use a site-readiness checklist covering construction, electrical, information technology, operations, and safety workstreams. |
Supplier should identify dependencies, provide installation drawings, and confirm commissioning prerequisites. |
Complete a readiness review before installation. Open issues should have an owner, due date, and documented risk treatment. |
High |
| Phase 4: Commissioning and testing |
Test normal missions, abnormal loads, communication loss, blocked paths, low battery, emergency stops, manual recovery, and restart behavior. |
Commission by zone or process segment so that problems can be isolated without disrupting the entire operation. |
Supplier should provide test scripts, configuration backups, training, and a defect-resolution process. |
Record test evidence and require formal sign-off for safety functions, interfaces, operational performance, and documentation. |
High |
| Phase 5: Controlled go-live |
Run the automated process alongside the existing method for a defined stabilization period, with trained operators available. |
Release production workload gradually and retain a documented fallback procedure for critical material movements. |
Supplier should provide on-site or rapid-response support during the initial operating period and review daily performance data. |
Use daily reviews for completed moves, faults, blocked time, manual interventions, safety observations, and open actions. |
High |
| Phase 6: Optimization and expansion |
After stabilization, analyze bottlenecks, route congestion, mission priorities, charging patterns, and utilization by vehicle. |
Increase fleet size or add processes only when the current workflow meets the agreed safety and performance targets. |
Supplier should support performance tuning, software updates, root-cause analysis, and expansion planning using actual operating data. |
Conduct a formal review at approximately 30, 60, and 90 days, then move to a recurring quarterly improvement cycle. |
Medium |
| 4. Practical Supplier-Selection Scorecard |
| Technical and operational fit |
25% suggested weighting |
Payload, navigation, throughput, battery strategy, floor compatibility, and environmental performance. |
Score only against documented requirements and demonstrated test results. |
Use a weighted bid comparison and record any assumptions or exceptions. |
High |
| Safety and compliance |
20% suggested weighting |
Protective functions, risk-assessment support, emergency behavior, documentation, and training. |
Do not offset unresolved safety gaps with a lower purchase price. |
Require documented closure of safety actions before production acceptance. |
High |
| Integration and software |
20% suggested weighting |
Fleet management, interfaces, cybersecurity, reporting, map management, and system scalability. |
Evaluate a live demonstration using representative mission scenarios and failure cases. |
Include interface tests and software acceptance criteria in the project plan. |
High |
| Service capability |
15% suggested weighting |
Local support, response times, spare parts, preventive maintenance, training, and warranty coverage. |
Validate service claims with references from comparable operating environments. |
Set measurable service-level targets and escalation contacts in the agreement. |
Medium |
| Total cost of ownership |
15% suggested weighting |
Acquisition, integration, infrastructure, software, maintenance, energy, labor impact, and expansion costs. |
Compare equivalent scope and a common planning period; separate one-time and recurring costs. |
Review the business case using actual pilot data before approving major expansion. |
High |
| References and project governance |
5% suggested weighting |
Relevant deployments, project management, change control, documentation, and communication practices. |
Check whether the supplier can provide accountable project leadership and clear issue ownership. |
Use a responsibility matrix, milestone plan, risk register, and formal change-approval process. |
Medium |

Fabricator
Inside Sales and Client Support Manager
Glass Handler – 1st Shift